Just now, the world's first robot brain API has been officially opened. The DreamZero team from NVIDIA has spun off to start its own business, with Ge Yunhao serving as CTO.
Today, Dream Labs, founded by the DreamZero team, officially came out of stealth mode and announced the completion of a $90 million seed round of financing, alongside the launch of Dream API: the world's first robot brain API open to the general public.
This means anyone can integrate the Dream API into their own robots. By simply providing natural language instructions, the Dream API can generate corresponding motor control commands to make the robots perform tasks. More importantly, it can also adapt to robots that have never been seen during training.
More than 20 hardware manufacturers have joined the cooperation so far.
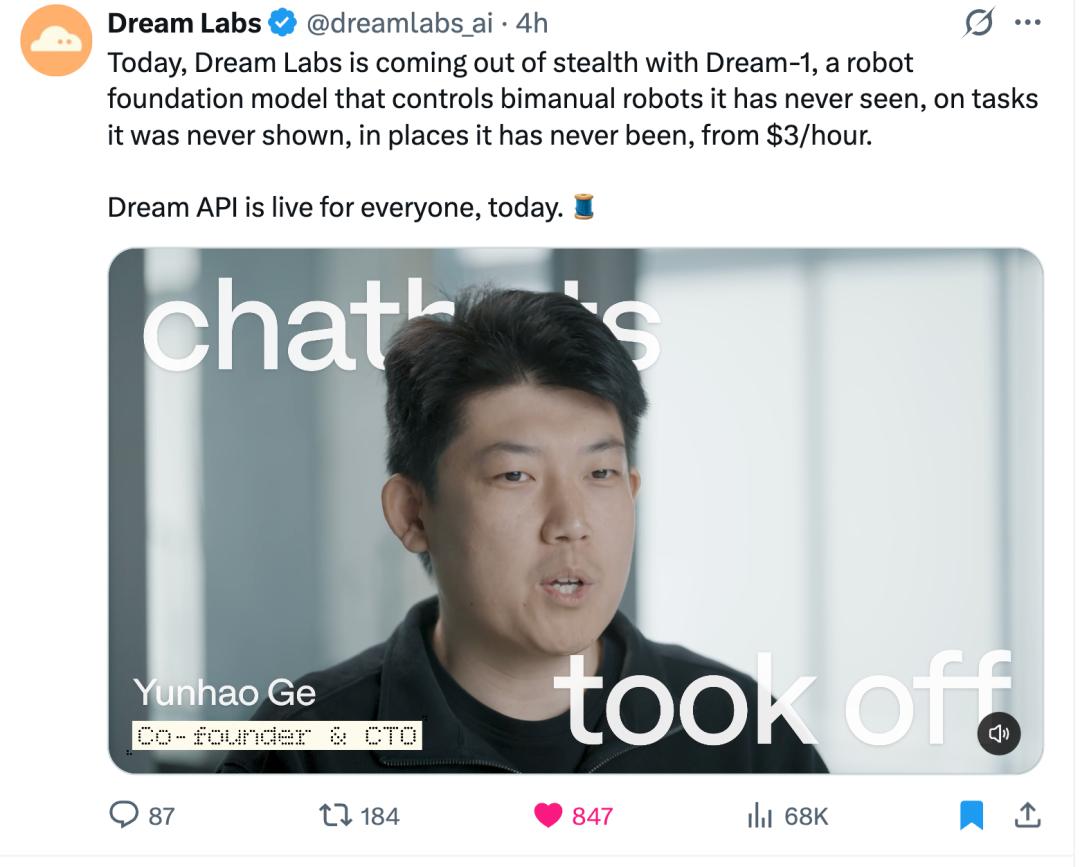
This team from Nvidia first proposed the World Action Model (WAM) in February this year, and WAM has now become one of the most popular tracks in embodied intelligence.
Powered by Dream Labs' first model Dream-1, the Dream API can control robots in real time with closed loops. Developers do not need a machine learning background to integrate this capability into their own robots, with a usage price of only $3 per hour. Anyone can visit the official website at dreamlabs.ai to try it out.
This round of financing is led by B Capital, with participation from Kindred Ventures, A.Capital, Unusual Ventures, SV Angel, Wing VC, Scribble VC and Adrian Aoun, among other institutions and individuals.
Robots are in lack of a general-purpose brain
A record 5 million industrial robots are operating in factories around the world, but almost every one of them is programmed for a single task, and the knowledge it learns cannot be transferred to another machine.
At the same time, robot hardware is rapidly getting cheaper: a set of dual-arm manipulators costs as low as about $2000, and semi-humanoid robots priced below $15,000 are becoming more and more common. Yet almost none of these robots come with a "brain" out of the factory. Teaching a robot to do one task often takes experts several months; if you change the task or replace the hardware, you have to start all over again.
The reason why chatbots have gained rapid popularity is that a general-purpose model allows anyone to use it as long as they turn on their computer or mobile phone. From the perspective of Dream Labs, robots also need to usher in such a moment. Only cheap hardware paired with a model that supports zero-shot generalization can make the data flywheel spin: the earlier robots become useful, the more people will use them, generating more data, and the model will become even better.
Dream API: a robot brain open to all
In the past, if you wanted to apply a foundation model to a robot, you usually had to train it on your own or conduct in-depth cooperation with manufacturers. Dream API is the world's first robot foundation model API open to the public: after registration, developers can connect their robots to the API and start using it immediately. The model is deployed in multiple data centers around the world, enabling fast response no matter where the robot is located.
There are two supporting services around the Dream API:
- Fine-tuning (FaaS): When encountering unsupported hardware or new tasks, developers and robot manufacturers can submit a small amount of demonstration data, and get a customized model within a few hours. For a new robot, a 5-minute trajectory is enough to complete the adaptation: among 10 partner robots participating in the Beta test, 10 of them have seen their Language following scores improved.
- Robot Playground: You don't need to buy a robot. You can open a browser to send instructions to the real robots in Dream Labs' San Francisco office, watch its reactions in real time, and the whole process is uncut.
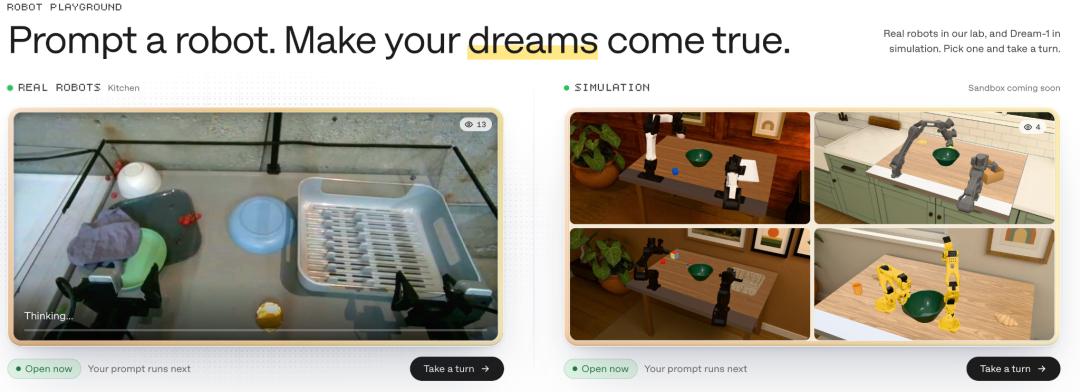
In terms of pricing, in addition to Dream-1 at $3 per hour, there is also the faster and lighter Dream-1-flash at $2 per hour.
Ge Yunhao, co-founder and CTO of Dream Labs, said: "Just like the first public release of ChatGPT, robots have finally welcomed the first general-purpose brain API open to the public. It may not be perfect, but someone has to take the first step."
Dream-1: Learn to "cross different robot bodies" from videos
Dream-1 can work on robots from different manufacturers. It is trained on videos of people completing daily tasks, learns to predict what will happen next, and then determines the actions the robot should take accordingly. Because it learns from videos instead of from a single machine, the capabilities it acquires can be transferred between different hardware: for dual-arm robots with grippers, Dream-1 can be used out of the box with zero-shot generalization.
Joel Jang, co-founder and CEO of Dream Labs, made an analogy: "When you sit in a rented car, you don't need to re-learn how to drive. You just find the controls, and your past driving experience will handle the rest. Dream-1 treats new robots the same way: a new robot can do useful work in a few minutes, not months."
Why can learning from videos achieve cross-body generalization? Ge Yunhao told Synced: "The World Action Model learns to predict videos and actions at the same time, so 'controlling a robot' and 'imagining what this robot will do next' become the same problem. From the perspective of the head-mounted camera, any robot is just a moving shape in the frame, and video is the shared representation for all robots. As long as the model can predict what a new robot will look like when it completes a task, it can generate the actions that make the robot reach that state."
Zero-shot availability for unseen robots and untaught tasks
The team evaluated 27 types of robots that Dream-1 had never seen before in simulation, including Unitree R1, Baxter, dual-arm UR5e, ALOHA, etc., with 300 rollouts run for each type. Taking the performance of YAM as 100%, 24 of them reached more than half of the score, and the highest dual-arm PiPER reached 91.2%.
On real machines, Dream-1 also achieved zero-shot control of partner robots such as MakerMods' Metal Arm and Maker Arm, Seeed Studio's reBot B601-DM, Anvil Robotics' OpenYAM, and Dexmate's Vega without any specific body data, completing instructions such as stacking towels, closing drawers, hanging headphones on hooks, and "putting fruits that are not kiwis into the basket".
It can also complete unseen tasks in environments it has never been to. Beta test partners ran Dream-1 independently at 9 sites around the world, including AGIBOT in Shanghai, BitRobot in Shenzhen, KAIST in Seoul, Hugging Face in Paris, Scale AI in San Francisco, etc., with tasks ranging from putting screwdrivers into boxes, folding boxes, to sorting tools into storage boxes.
At present, Dream-1 mainly handles desktop tasks, such as grasping and placing objects, and folding clothes. Dual-arm parallel gripper robots can be used without additional data; for more than 20 hardware partners, Dream Labs will further optimize the model for each robot, and the price of these robots ranges from about $2000 to $10,000.
Large models can directly control robots, do we still need robot-specific brains?
Recently, general large models such as GPT-6 Astra have been directly connected to manipulators to control robots to work, and many people have begun to worry: will the specially trained robot foundation models be replaced by large general models?
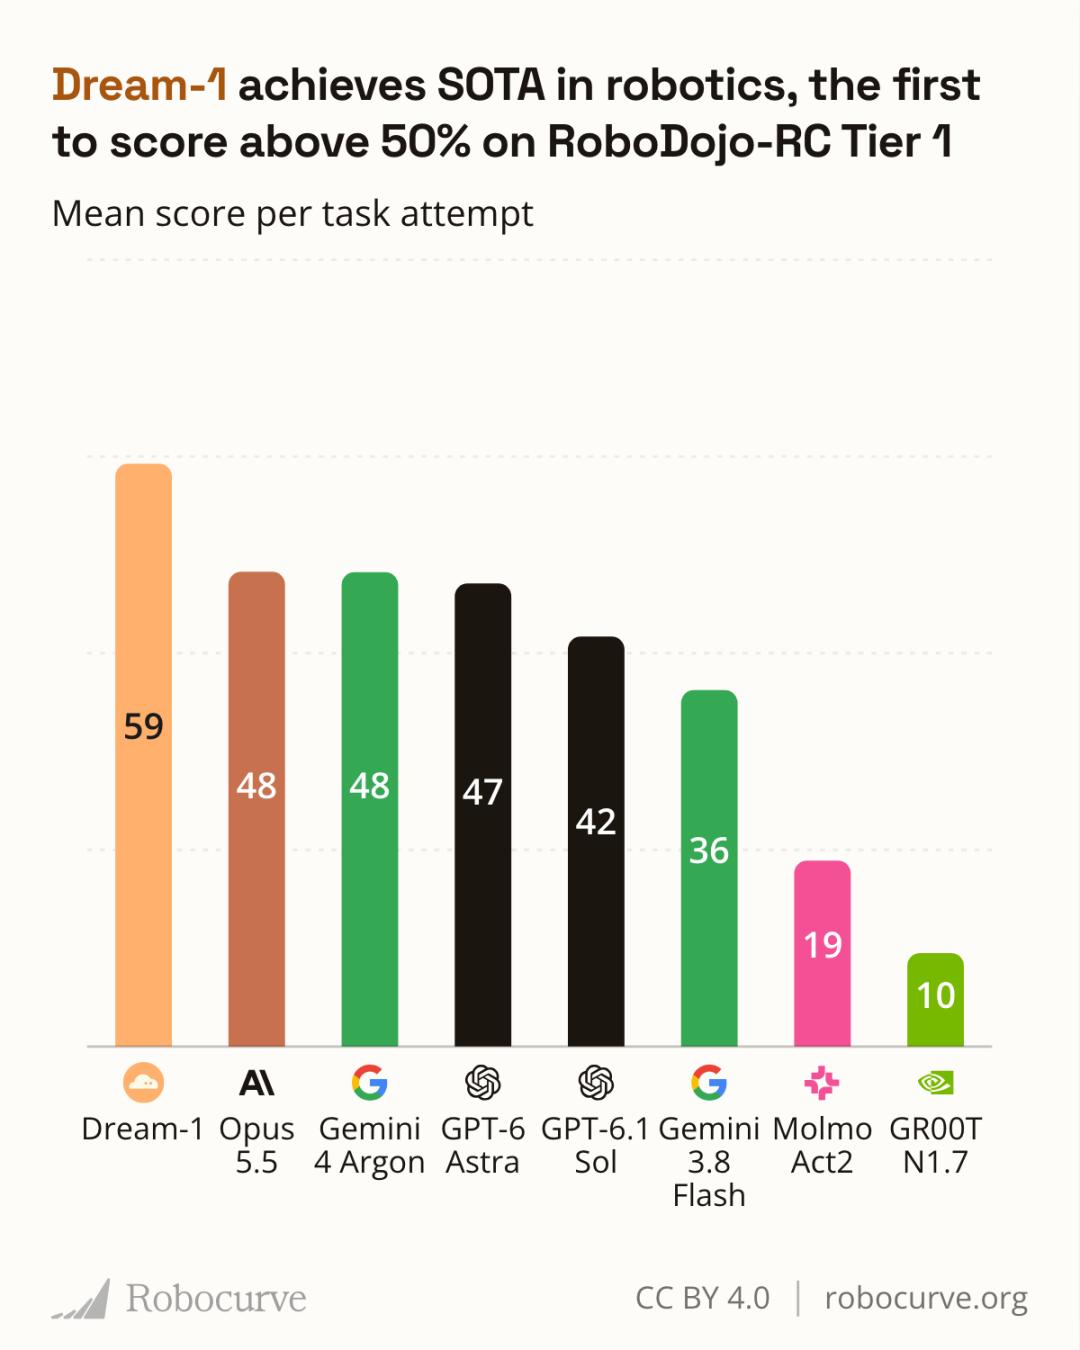
In the RoboDojo-RC Tier 1 evaluation released by the independent third-party evaluation agency Robocurve, Dream-1 achieved an average score of 59% per task attempt, making it the first model to exceed 50%, higher than the latest large models such as Claude Opus 5.5 (48%), Gemini 4 Argon (48%), GPT-6 Astra (47%), GPT-6.1 Sol (42%), and also higher than robot models such as MolmoAct2 (19%) and GR00T N1.7 (10%).
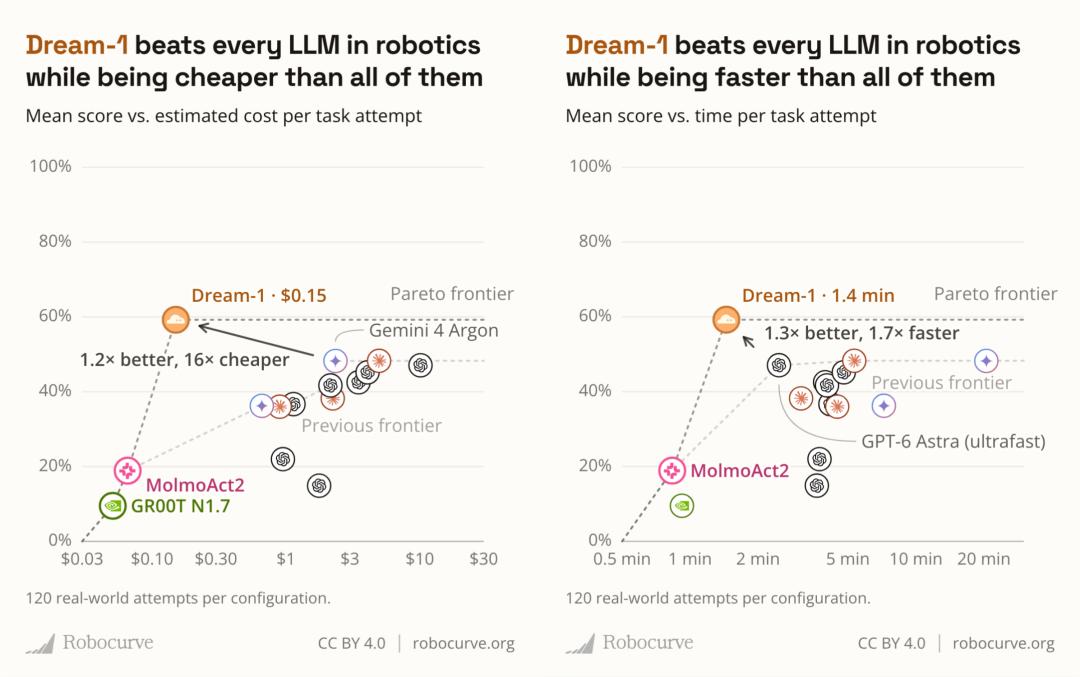
Not only does it have a higher score, Dream-1 is also cheaper and faster: the cost per task attempt is about $0.15. Compared with Gemini 4 Argon, which has the second highest score, Dream-1 has a 1.2 times higher score while the cost is about 16 times lower. The average time taken is 1.4 minutes. Compared with GPT-6 Astra (ultrafast), the fastest large model, Dream-1 has a 1.3 times higher score and is 1.7 times faster. Each model configuration has been tested 120 times in the real world.
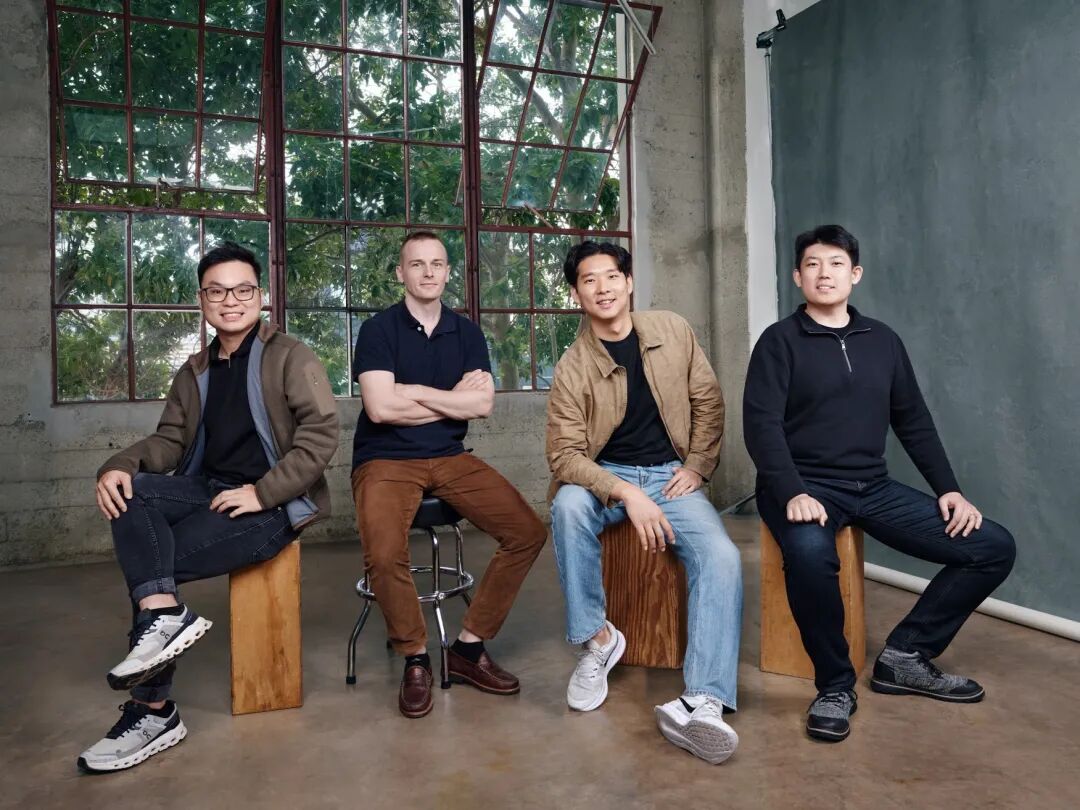
Four core members from Nvidia GR00T
The four co-founders all come from Nvidia's GR00T robotics team:
- Joel Jang (Co-founder and CEO): Head of Nvidia GR00T World Model, led the development of LAPA, DreamGen, DreamDojo and DreamZero;
- Ge Yunhao (Co-founder and CTO): Head of Nvidia GR00T Video Model, participated in the construction of Nvidia Cosmos world foundation model series (Predict, Transfer, Policy), with rich experience across Stanford, University of Southern California, Google and Microsoft;
- Scott Reed (Co-founder and Chief Scientist): Founding member of Nvidia GEAR Lab, led the development of GR00T N1 to N1.7 series of models; previously worked at DeepMind for 8 years, created Gato and Genie, with more than 158,000 citations on Google Scholar;
- You Liang Tan (Co-founder and Chief Robot Officer): Head of Nvidia GR00T Open Source, participated in the construction of ROS 2, Octo, SERL, EgoScale, and is a full-stack robotics expert.
In February this year, when the team was still at Nvidia, they released DreamZero, which for the first time clearly proposed the World Action Model (WAM). In the following six months, WAM quickly became one of the most popular tracks in embodied intelligence.
What surprised the team the most at that time was that DreamZero only used 30 minutes of YAM robot data for post-training, and it achieved zero-shot generalization to unseen tasks, which in the past often required hundreds or even thousands of hours of specific body data. If 30 minutes of data is enough, the vicious cycle of robots being "useless without data and no data because they are useless" can potentially be broken. The team thus decided to start their own business. Six months later, Dream-1 was launched.
Daisy Cai, General Partner of lead investor B Capital, said: "The price of a functional manipulator has dropped from the price of a luxury car to the price of a high-end laptop, and what it lacks now is intelligence. This team has completed some pioneering work in the field of robot learning at Nvidia, and now anyone who gets the Dream API can build on top of it."
Limitations and next steps
Dream-1 is currently in the research Beta version, and the team has also clearly stated its limitations:
- Its performance depends on the quality of the IK solver of each robot;
- It only determines the final position of the gripper, and does not control how the arm moves to reach that position, which may cause problems near obstacles or at joint limits;
- When facing a robot body that is very different from the robots it has seen, it may generate infeasible predicted actions.
Joel Jang said: "We don't show you edited demos. Instead, we give you a truly usable model that you can test by yourself, along with all its flaws."
There is still a gap between zero-shot capability and one-shot adaptation. Ge Yunhao said: "What we really want is to not even need those 5 minutes of data. Closing the gap between zero-shot and one-shot adaptation is our top priority in the next stage."
In the next step, Dream-1 will support wheeled mobile robots and dexterous hands. This round of financing will be mainly used for computing power, to expand the types of tasks and robots that Dream-1 can handle, and to support more users.
In the robot world where hardware is getting cheaper and cheaper yet still lacks a "brain", how far can a model that can directly take over unfamiliar robots go? Dream-1 has delivered the first testable answer that everyone can verify by themselves.
Reference links:
https://dreamlabs.ai/
https://dreamlabs.ai/research/dream-1
This article is from the WeChat official account Synced, authorized for release by 36Kr.